Pololu Blog »
Self-balancing robot
Posted by Paul on 25 September 2012
0 comments
Tags: community projects
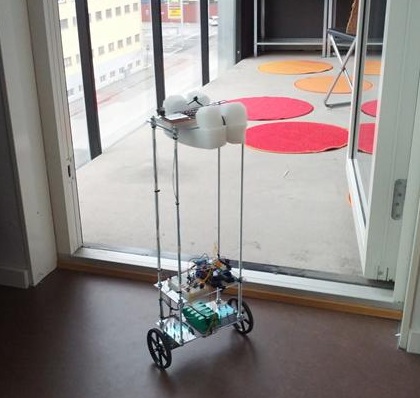 |
This self-balancing by Sebastian Nilsson robot uses a 37D metal gearmotor with encoder and a pair of Pololu 90×10mm wheels.
Featured link: http://sebastiannilsson.com/en/k/projekt/selfbalancing-robot/
-
Pi Trak
- 25 September 2012This Raspberry Pi-based robot’s motors are driven with a TB6612FNG motor driver carrier.
-
HeadlMU tracking
- 25 September 2012This head tracking project uses a MinIMU-9 v2 and an Arduino to mimic the movement of a person in a computer-generated model.
0 comments
Post a comment


Home | Forum | Blog | Support | Ordering Information | Lists | Distributors | BIG Order Form | About | Contact
© 2001–2026 Pololu Corporation