Pololu Blog »
Quaternion-based AHRS using AltIMU-10 & Arduino
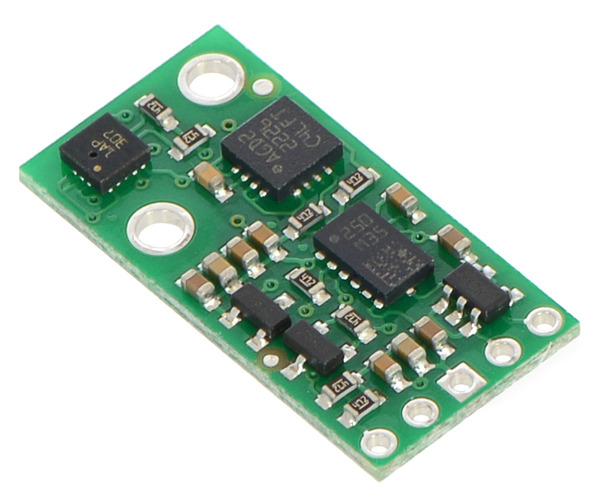 |
Pololu forum user Camel recently posted the Quaternion-based AHRS using AltIMU-10 & Arduino. This is an Arduino program that can read data from our AltIMU-10 sensor board, compute the orientation of the board, and output it over serial. It uses quaternions internally to represent the rotation, but can output Euler anglers, a rotation matrix, or a quaternion. The MinIMU-9 v2 is just an AltIMU-10 without a pressure sensor, so the code can be made to work with a MinIMU-9 v2 by commenting out a few lines.
The AHRS program is part of the Firetail UAV System, an open source UAV autopilot system that is currently under development. You can follow the the project’s progress on its blog.
-
New product: LSM303D 3D Compass and Accelerometer Carrier
- 15 November 2013As smartphones and tablets become more popular and more advanced, they drive the rapid development of progressively better and cheaper inertial...
0 comments
Post a comment


Home | Forum | Blog | Support | Ordering Information | Lists | Distributors | BIG Order Form | About | Contact
© 2001–2026 Pololu Corporation